Multipath, Jamming and 100 Hz: What a Port Straddle-Carrier Retrofit Teaches UAV Integrators
A container yard is a worst-case GNSS environment: steel, reflections, moving machinery. What the PSA Antwerp retrofit means for drone integrators.
Step-by-step tutorials for integrating GNSS receivers with PX4, ArduPilot, and Pixhawk
A container yard is a worst-case GNSS environment: steel, reflections, moving machinery. What the PSA Antwerp retrofit means for drone integrators.
A Mosaic-G5 P3H field test measured Galileo HAS at 10 cm in open sky – about 5 minutes to 20 cm and 12 minutes to 10 cm.
How the official Septentrio ROSaic driver (septentrio_gnss_driver) brings mosaic-X5 and AsteRx GNSS/INS receivers into ROS 1 and ROS 2 for UAVs.
Why RxTools is the professional configuration and diagnostics software for Septentrio GNSS receivers: Linux support, spectrum analysis and command control.
Septentrio mosaic-G5 and Pixhawk integration guide: UART and DroneCAN wiring, PX4 and ArduPilot config, RTK centimeter positioning and heading.
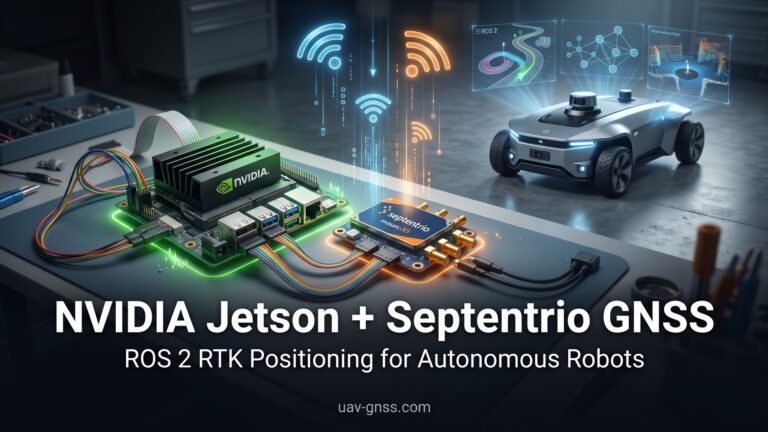
A complete guide to integrating Septentrio mosaic-X5 and mosaic-G5 GNSS receivers with NVIDIA Jetson Orin running ROS 2 — from wiring to RTK positioning.
How to integrate Septentrio RTK GNSS receivers with the CUAV V5+ flight controller: wiring diagrams, ArduPilot and PX4 parameters, benchmarks.
If you fly an Autel EVO Max 4T or EVO Max 4N for mapping, inspection, or security operations, you have a…
How to configure Septentrio GNSS receivers with RxTools and RxControl for UAVs: RTK setup, firmware updates, NMEA output and data logging.
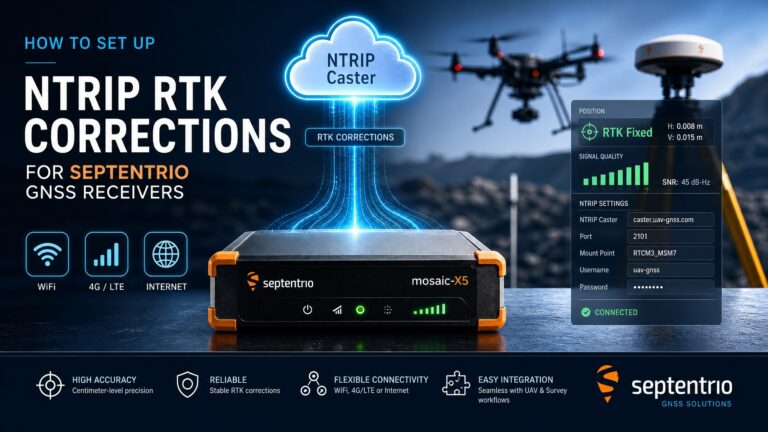
Step-by-step guide to setting up NTRIP RTK corrections for Septentrio GNSS receivers, with centimeter-level accuracy for UAV navigation.